Machine vision
Real-time weed perception in complex orchard rows
Overview
An attention-enhanced vision framework that detects, segments, tracks, localizes, and estimates the spatial density of intra-row weeds from a side-view camera.
Watch demonstrationsRead publication ↗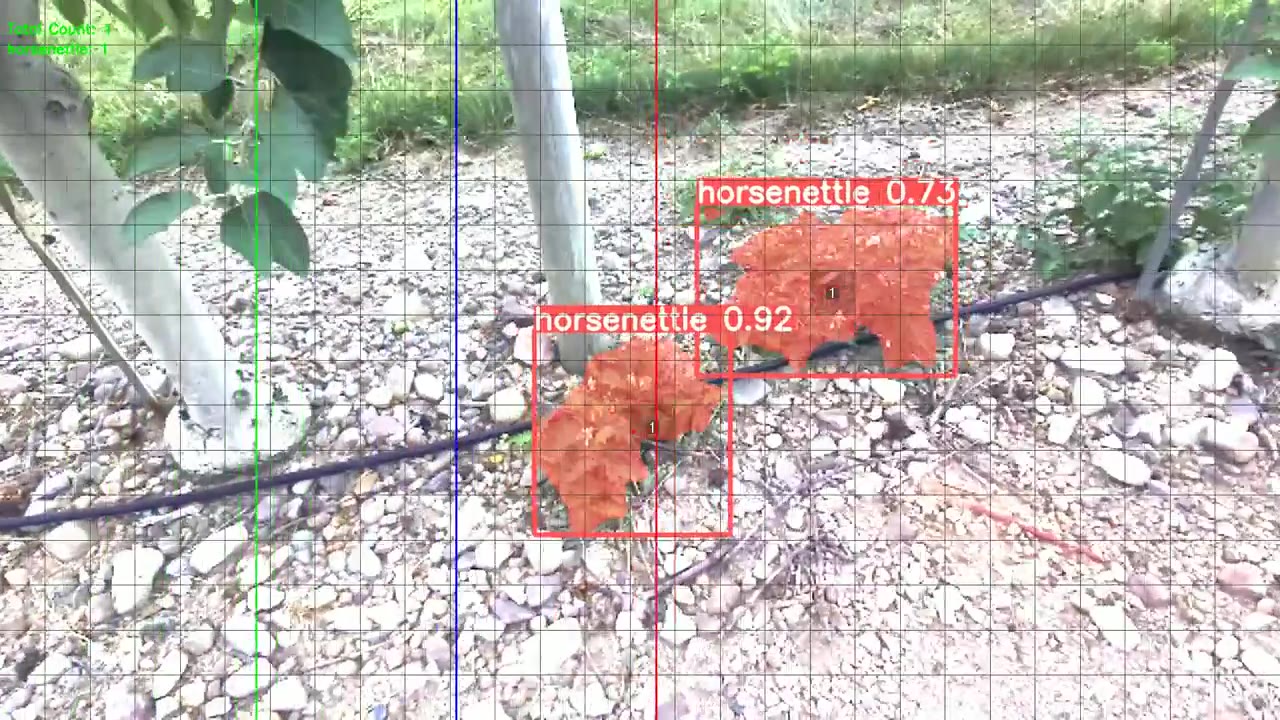
- Environment
- Apple orchards
- Model
- YOLOv7-Seg + CBAM
- Tracking
- Modified DeepSORT
- Input
- 1920 × 1080 video
Weed perception and its application
Two views of machine vision in practice: identifying and tracking weeds in orchard imagery, then using perception outputs in the spray-control interface.
Weed detection and identity tracking
Orchard imagery shows detection masks, persistent plant IDs, and spatial grids as weeds pass through the camera view. This recording focuses on identifying plants and maintaining their identities across frames.
1 / 2Perception-to-spray control interface
The operator interface brings detections together with weed-size estimates, nozzle assignments, and spray activity logs. This recording focuses on how perception outputs support targeted spray decisions.
2 / 2Research Challenge
Low branches, trunks, irrigation lines, shadows, and occlusion make orchard weeds difficult to see consistently.
Engineering Approach
- Build and annotate a multi-species orchard weed dataset.
- Enhance YOLOv7 segmentation with a convolutional block attention module.
- Preserve weed identities across frames with DeepSORT and filtering.
- Convert masks into a 20 × 20 pixel grid for localized density estimation.
Significance
The system turns raw orchard video into stable, spatially actionable weed information for site-specific treatment.
Read the first-author journal article ↗