
Machine Vision
Orchard scenes contain overlapping plants, shadows, and changing viewpoints. I developed a vision pipeline combining weed segmentation, identity tracking, and spatial analysis to locate individual weeds and estimate intra-row density.
Computer vision, robotic control, and plant-informed decisions for precision agriculture. Explore the projects and watch the systems in action.
Orchard scenes contain overlapping plants, shadows, and changing viewpoints. I developed a vision pipeline combining weed segmentation, identity tracking, and spatial analysis to locate individual weeds and estimate intra-row density.
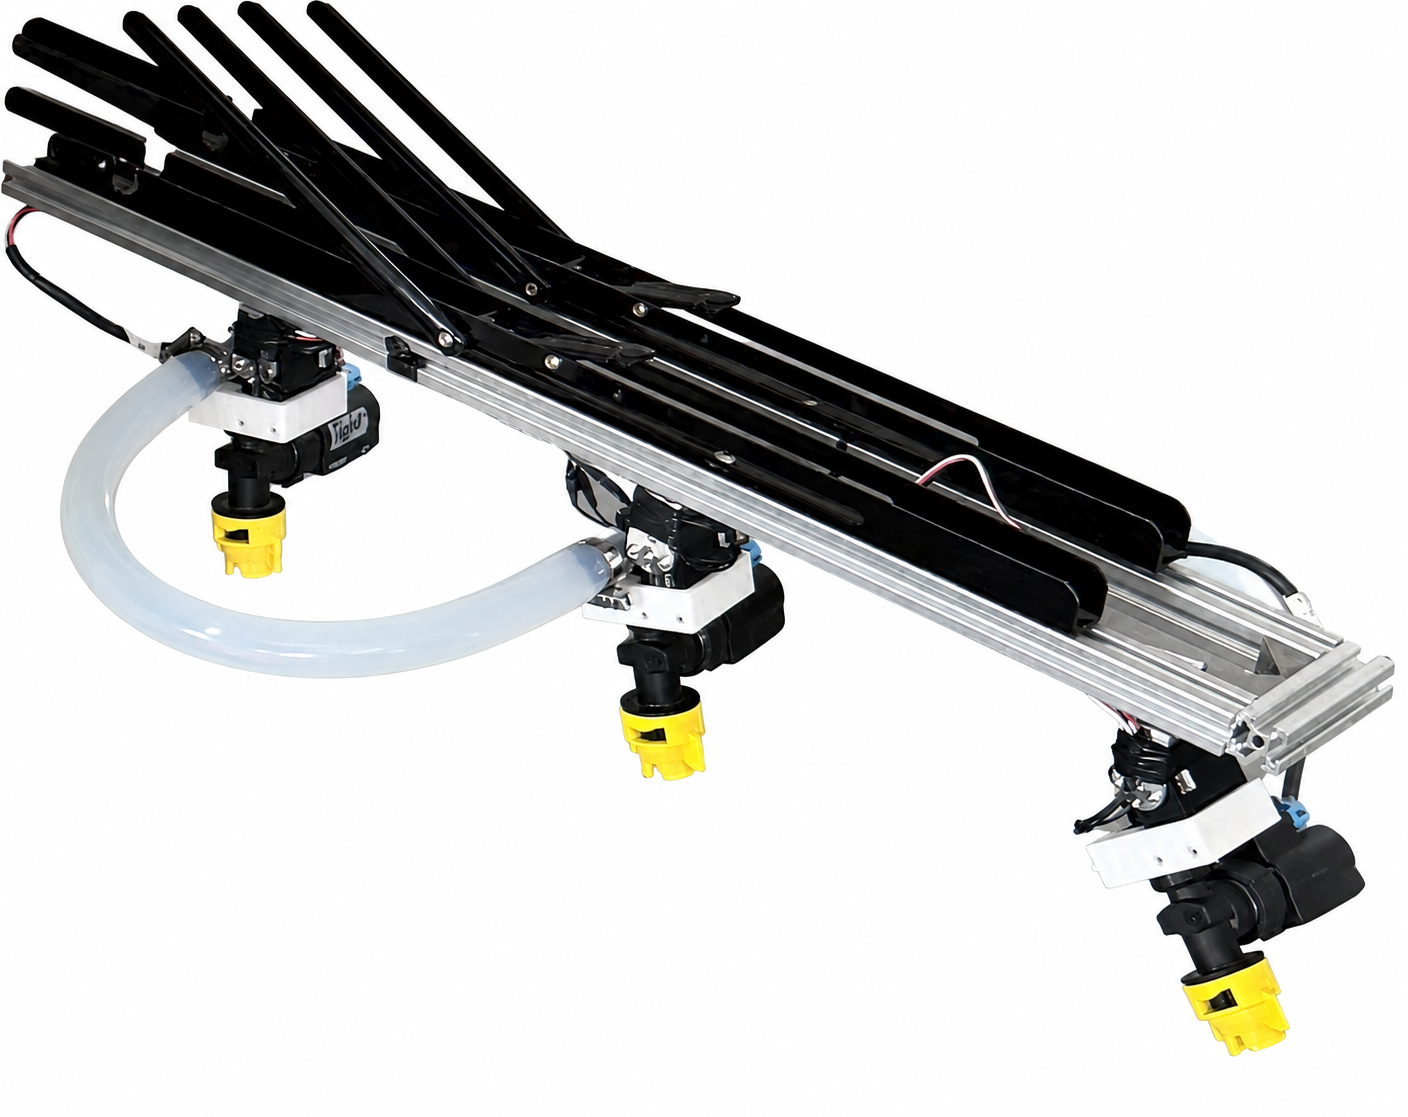
A detected weed must become a physical spray target. I designed and evaluated a three-nozzle servo-controlled system that translates target locations into nozzle assignments, steering commands, and spray timing, with laboratory validation of actuator and targeting performance.
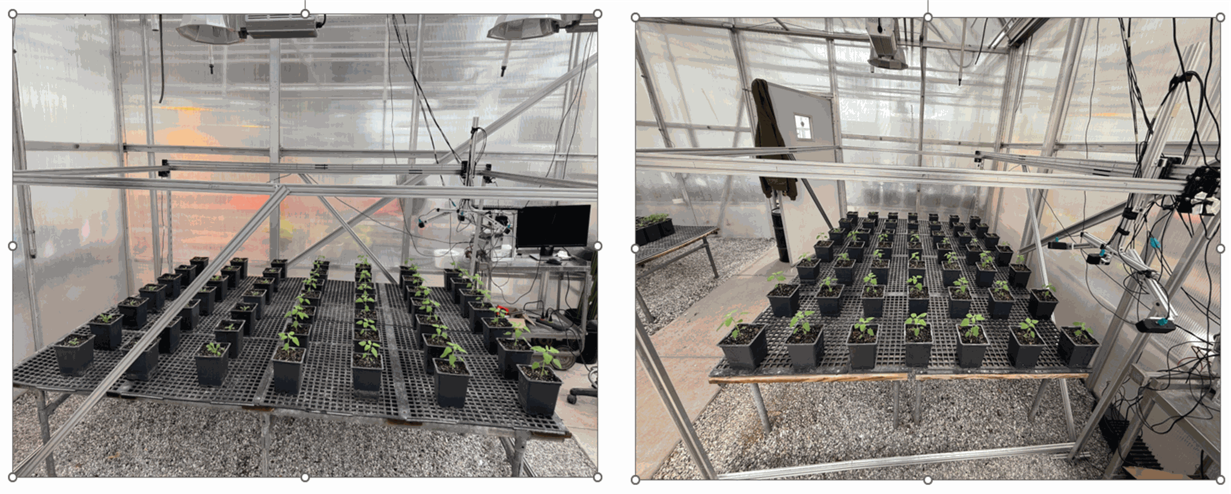
Weeds differ in canopy size and growth habit. I developed a calibrated imaging workflow to measure plant morphology and used controlled spray-deposition experiments to examine how plant and nozzle characteristics affect coverage and off-target deposition.
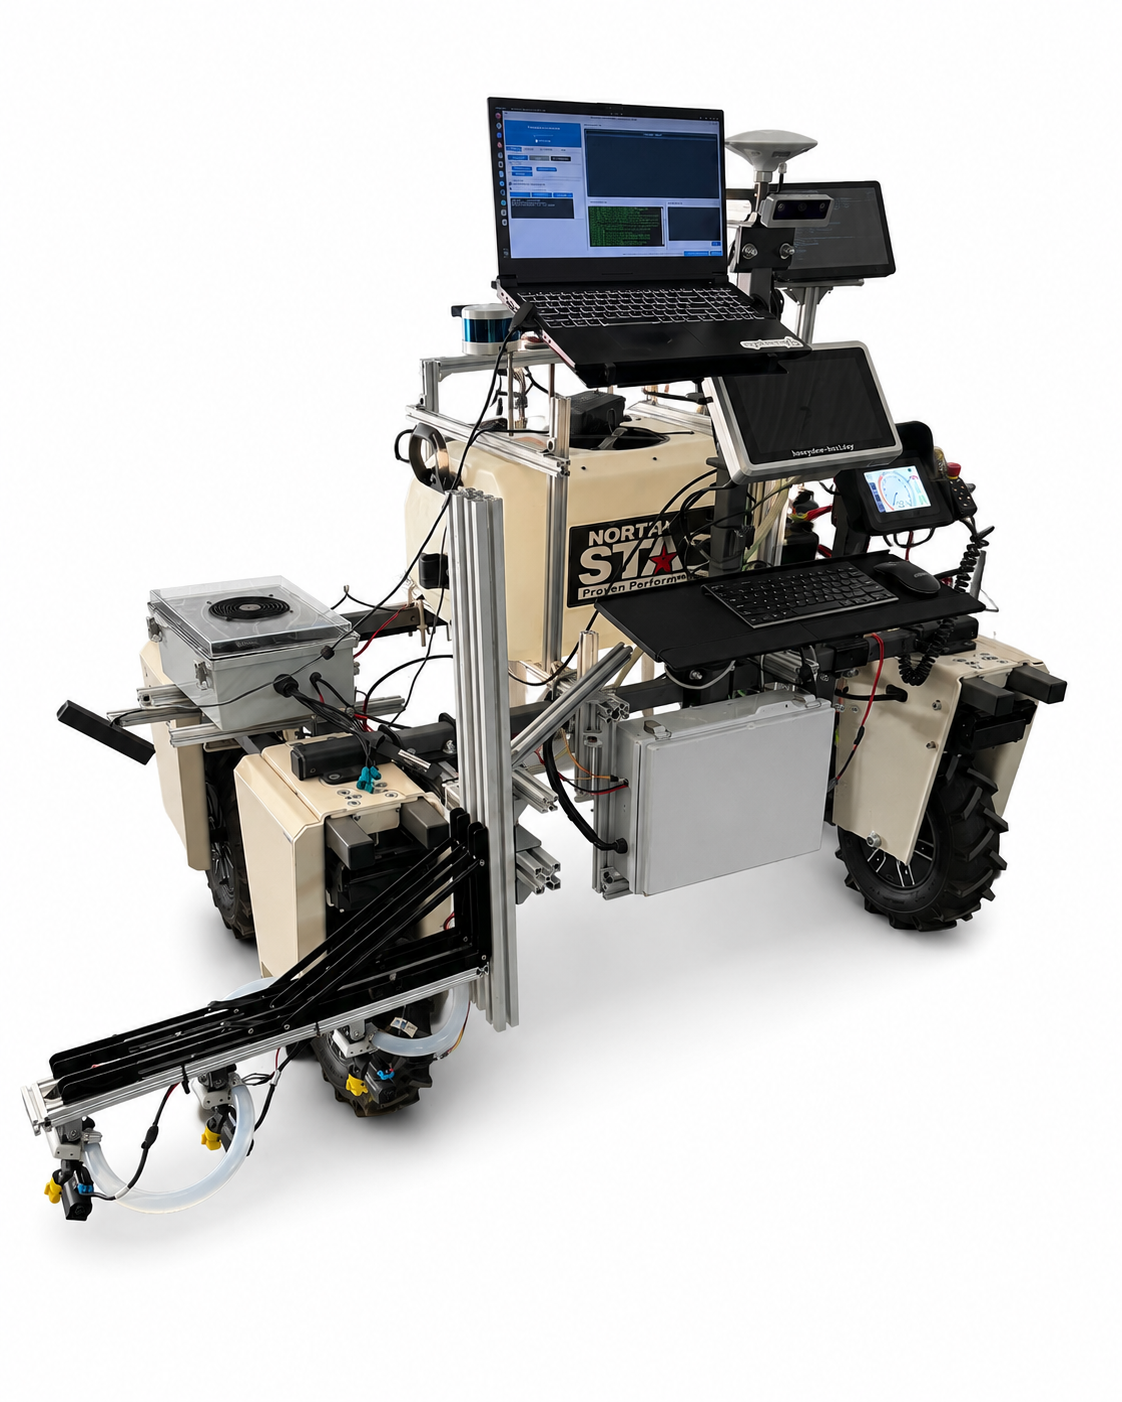
Perception and spraying must work together while the robot moves. I integrated target localization, spray decisions, and nozzle operation on a Farm-ng Amiga platform, with orchard field tests and an interface for live monitoring and control.