
Machine Vision
Orchard scenes contain overlapping plants, shadows, and changing viewpoints. I developed a vision pipeline combining weed segmentation, identity tracking, and spatial analysis to locate individual weeds and estimate intra-row density.
Agricultural robotics · Computer vision · Precision agriculture
I am a doctoral researcher in Agricultural and Biological Engineering at Penn State, working with Dr. Long He in the Ag Robotics & Sensing Lab. My research focuses on robotic and precision weed management, combining computer vision, machine learning, and robotic control to develop automated spraying systems for apple orchards.
Previously, I earned a B.Sc. in Agriculture and an M.Phil. in Agricultural Mechanization from the University of Cape Coast, Ghana. I also worked as a field officer with the Ghana Cocoa Board.
Connecting what robots see, how they act, and how treatment decisions are made.
Orchard scenes contain overlapping plants, shadows, and changing viewpoints. I developed a vision pipeline combining weed segmentation, identity tracking, and spatial analysis to locate individual weeds and estimate intra-row density.
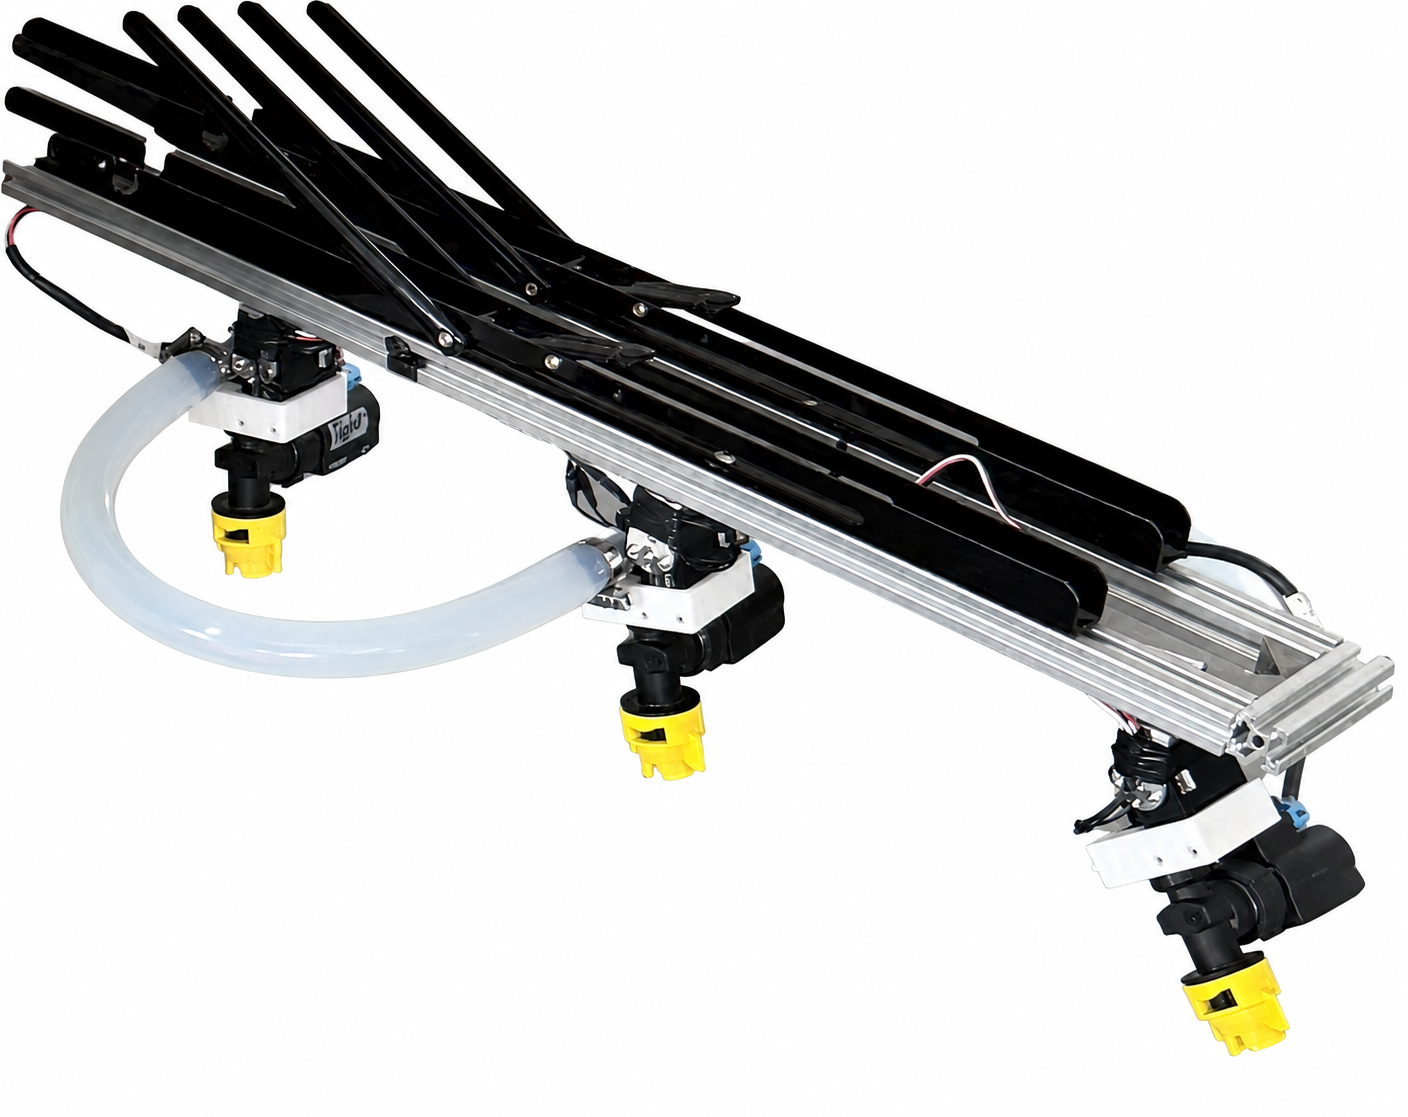
A detected weed must become a physical spray target. I designed and evaluated a three-nozzle servo-controlled system that translates target locations into nozzle assignments, steering commands, and spray timing, with laboratory validation of actuator and targeting performance.
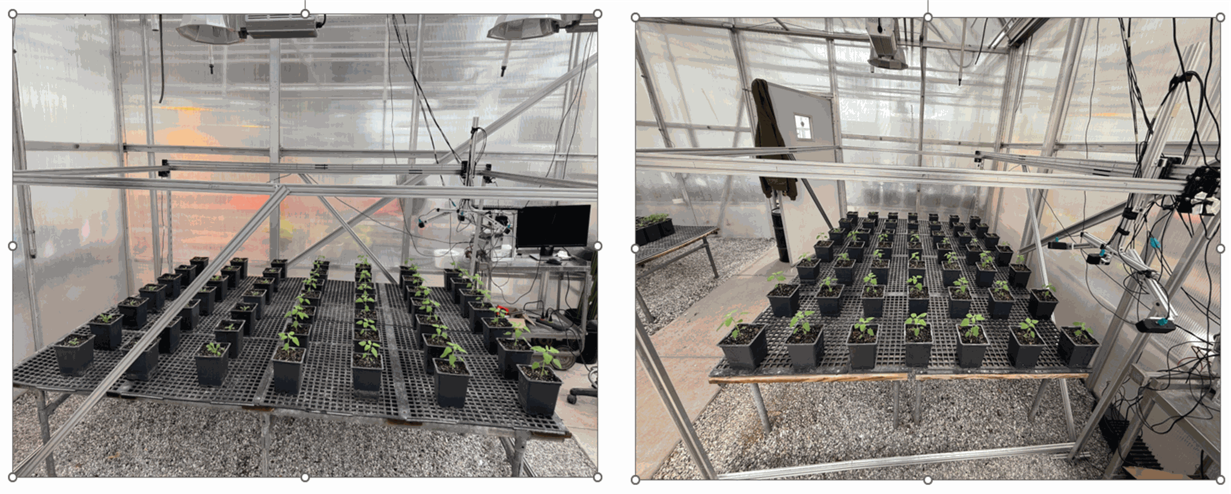
Weeds differ in canopy size and growth habit. I developed a calibrated imaging workflow to measure plant morphology and used controlled spray-deposition experiments to examine how plant and nozzle characteristics affect coverage and off-target deposition.
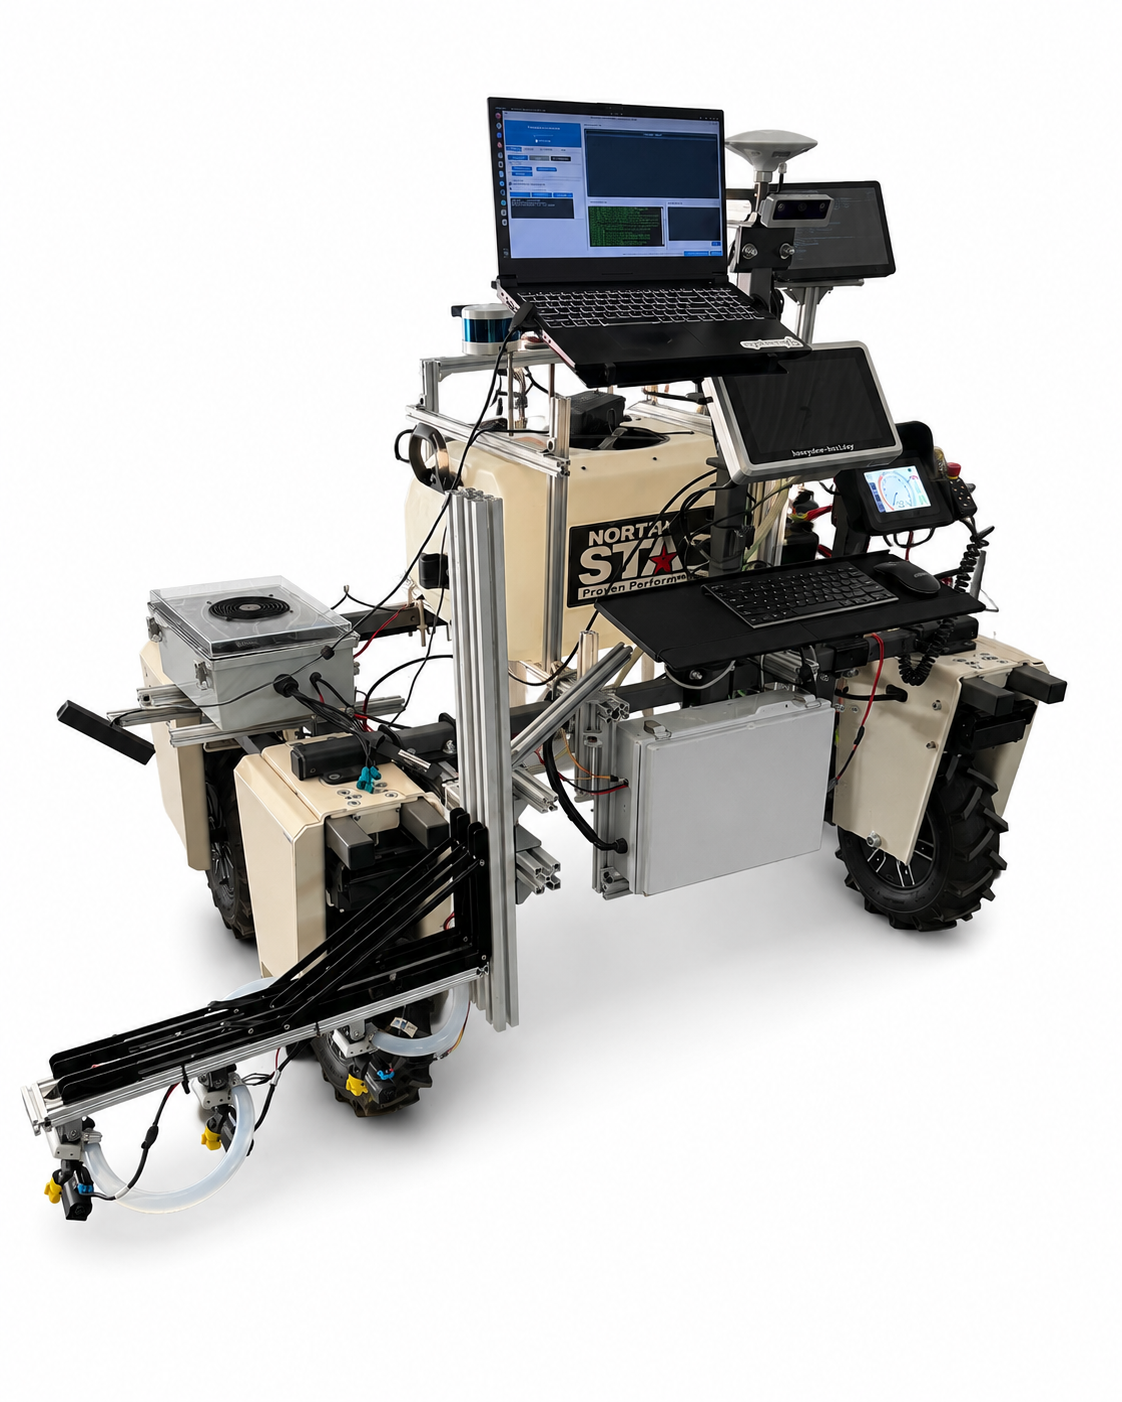
Perception and spraying must work together while the robot moves. I integrated target localization, spray decisions, and nozzle operation on a Farm-ng Amiga platform, with orchard field tests and an interface for live monitoring and control.
Arthur, L., Mahnan, S., He, L., Hussain, M., Heinemann, P., & Brunharo, C.
Computers and Electronics in Agriculture, 239, 111071 · 2025
Read article ↗Mahnan, S., Arthur, L., He, L., Ghatrehsamani, S., Heinemann, P., & Pecchia, J.
Computers and Electronics in Agriculture, 247, 111753 · 2026
Read article ↗Yang, Y., Mali, P., Arthur, L., Molaei, F., Atsyo, S., Geng, J., He, L., & Ghatrehsamani, S.
Computers and Electronics in Agriculture, 229, 109704 · 2025
Read article ↗As a Teaching Assistant at Penn State and the University of Cape Coast, I supported hands-on electronics laboratories, introductory engineering and quantitative courses, and student project work.
Teaching experience →I share agricultural robotics research through field demonstrations, grower events, school outreach, and media interviews, connecting technical work with the people who may use it.
Media coverage & outreach →